Robotics 3 min
Denavit–Hartenberg: Any Robot Arm in 4 Numbers per Joint
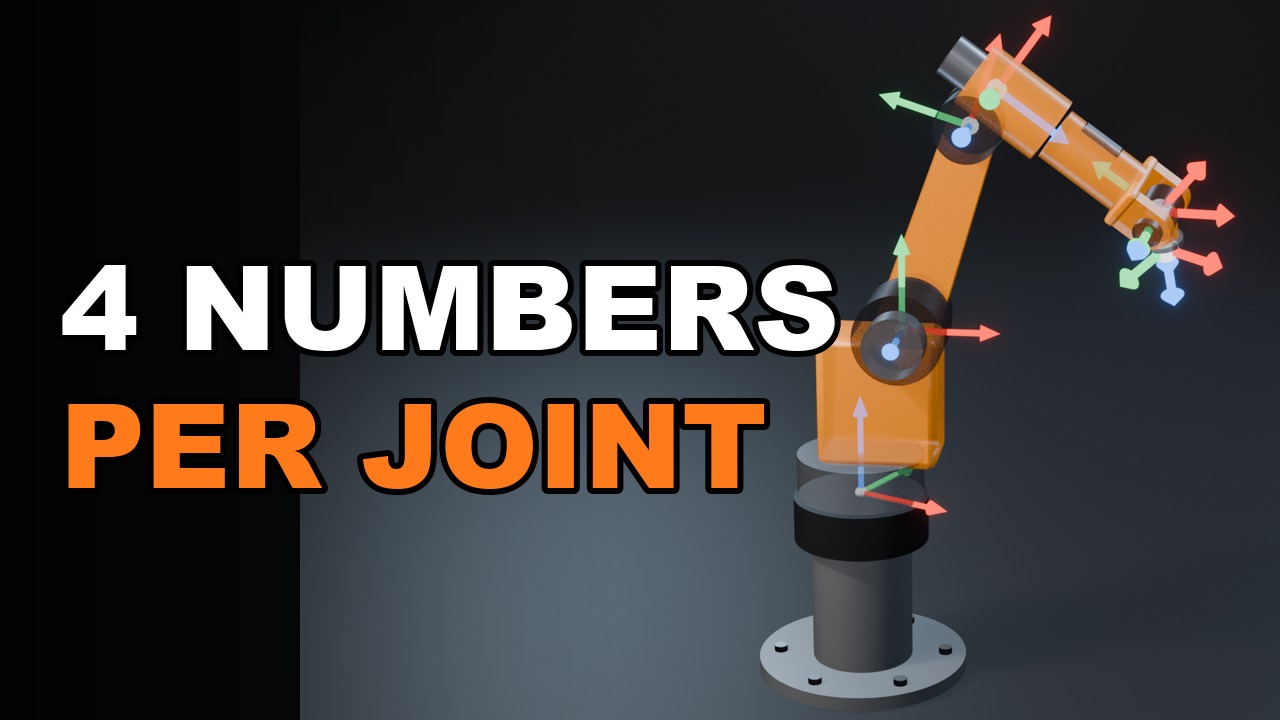
Six motors, six angles. Where exactly is the tip of the robot's tool? In 1955 Denavit and Hartenberg showed that four numbers per joint are enough to describe any arm, and a chain of small matrices answers the question. Robots still use it today.
The video assigns the frames, finds the common normal, builds the table, multiplies through to the tool tip, and shows the traps between the classic and modified conventions.
In this video
- A coordinate frame on every link
- d, θ, a, α: four numbers per joint
- The DH table and the forward kinematics product
- Classic versus modified conventions, inverse kinematics, calibration